CVPR 2024
A Simple and Effective Point-based Network for Event Camera 6-DOFs Pose Relocalization
Asterisk: Equal contribution.
In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR 2024), 18112–18121
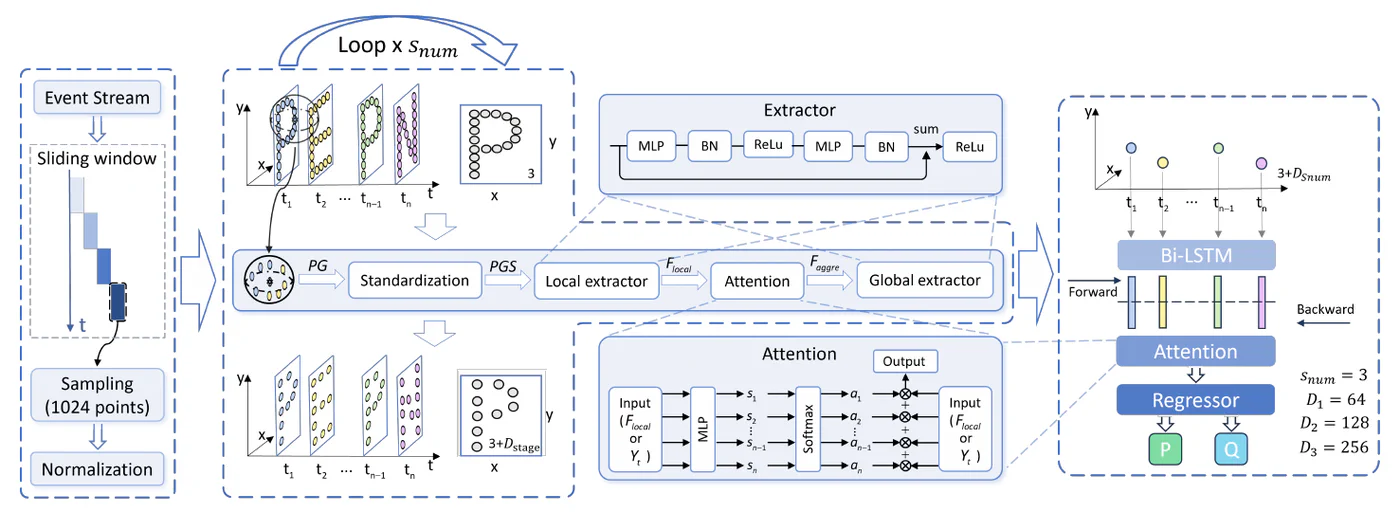
Overview
PEPNet estimates six-degree-of-freedom camera poses directly from event point clouds. Hierarchical modules extract spatial and implicit temporal features, while an attentive bidirectional LSTM captures explicit temporal relationships. Its lightweight design preserves the fine temporal resolution and sparsity of events for efficient indoor and outdoor pose relocalization.
BibTeX citation
@inproceedings{Ren_2024_CVPR,
  title = {A Simple and Effective Point-based Network for Event Camera {6-DOFs} Pose Relocalization},
  author = {Ren, Hongwei and Zhu, Jiadong and Zhou, Yue and Fu, Haotian and Huang, Yulong and Cheng, Bojun},
  booktitle = {Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
  year = {2024},
  pages = {18112--18121},
  publisher = {IEEE},
  doi = {10.1109/CVPR52733.2024.01715},
  url = {https://doi.org/10.1109/CVPR52733.2024.01715}
}